 All Posts
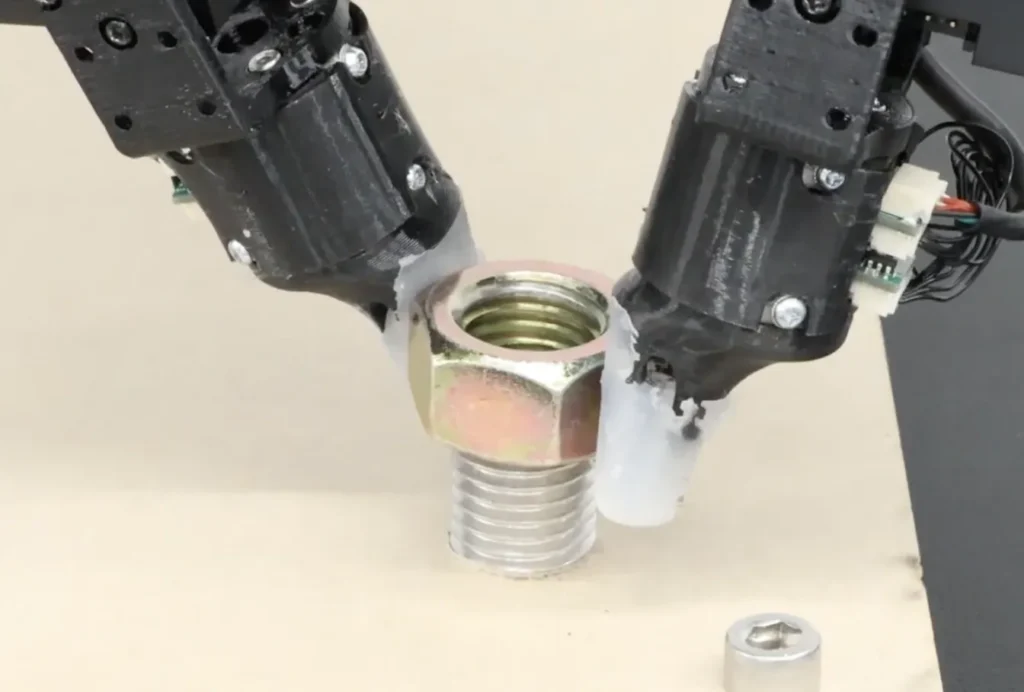
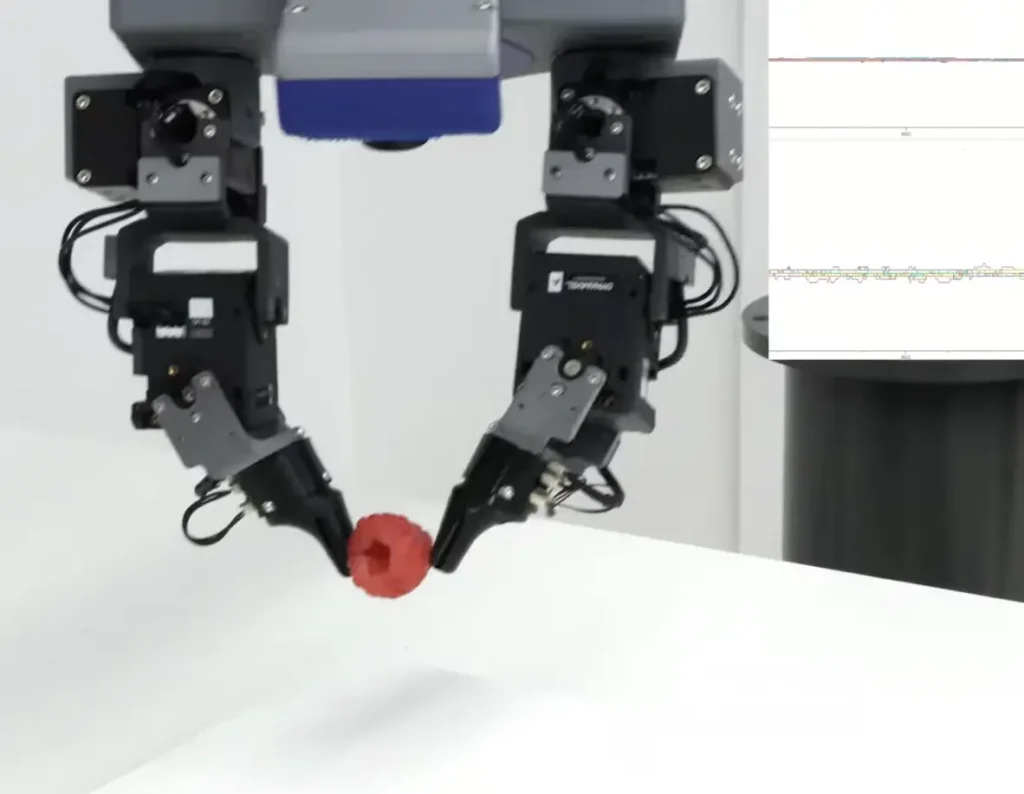
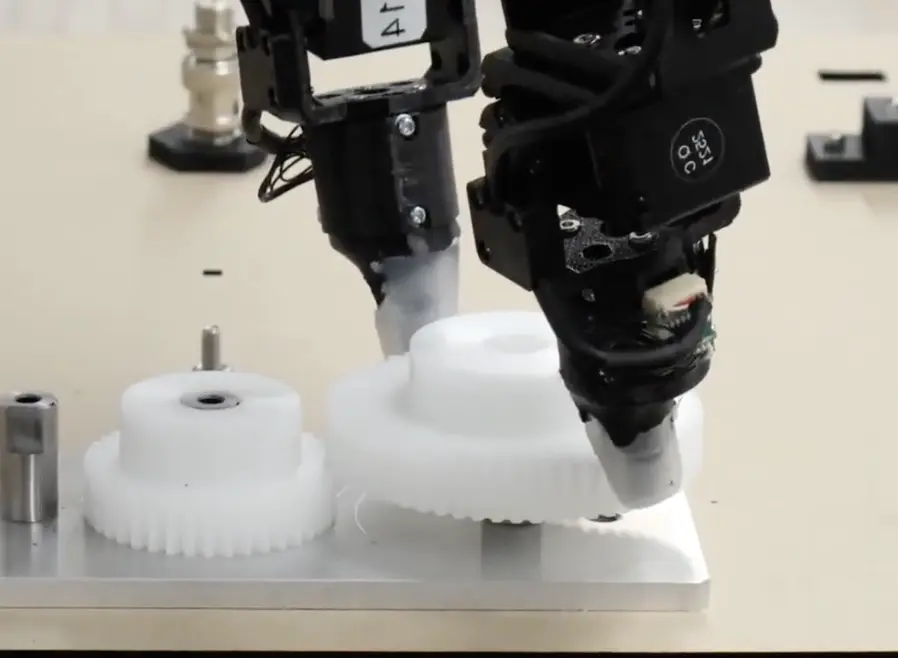
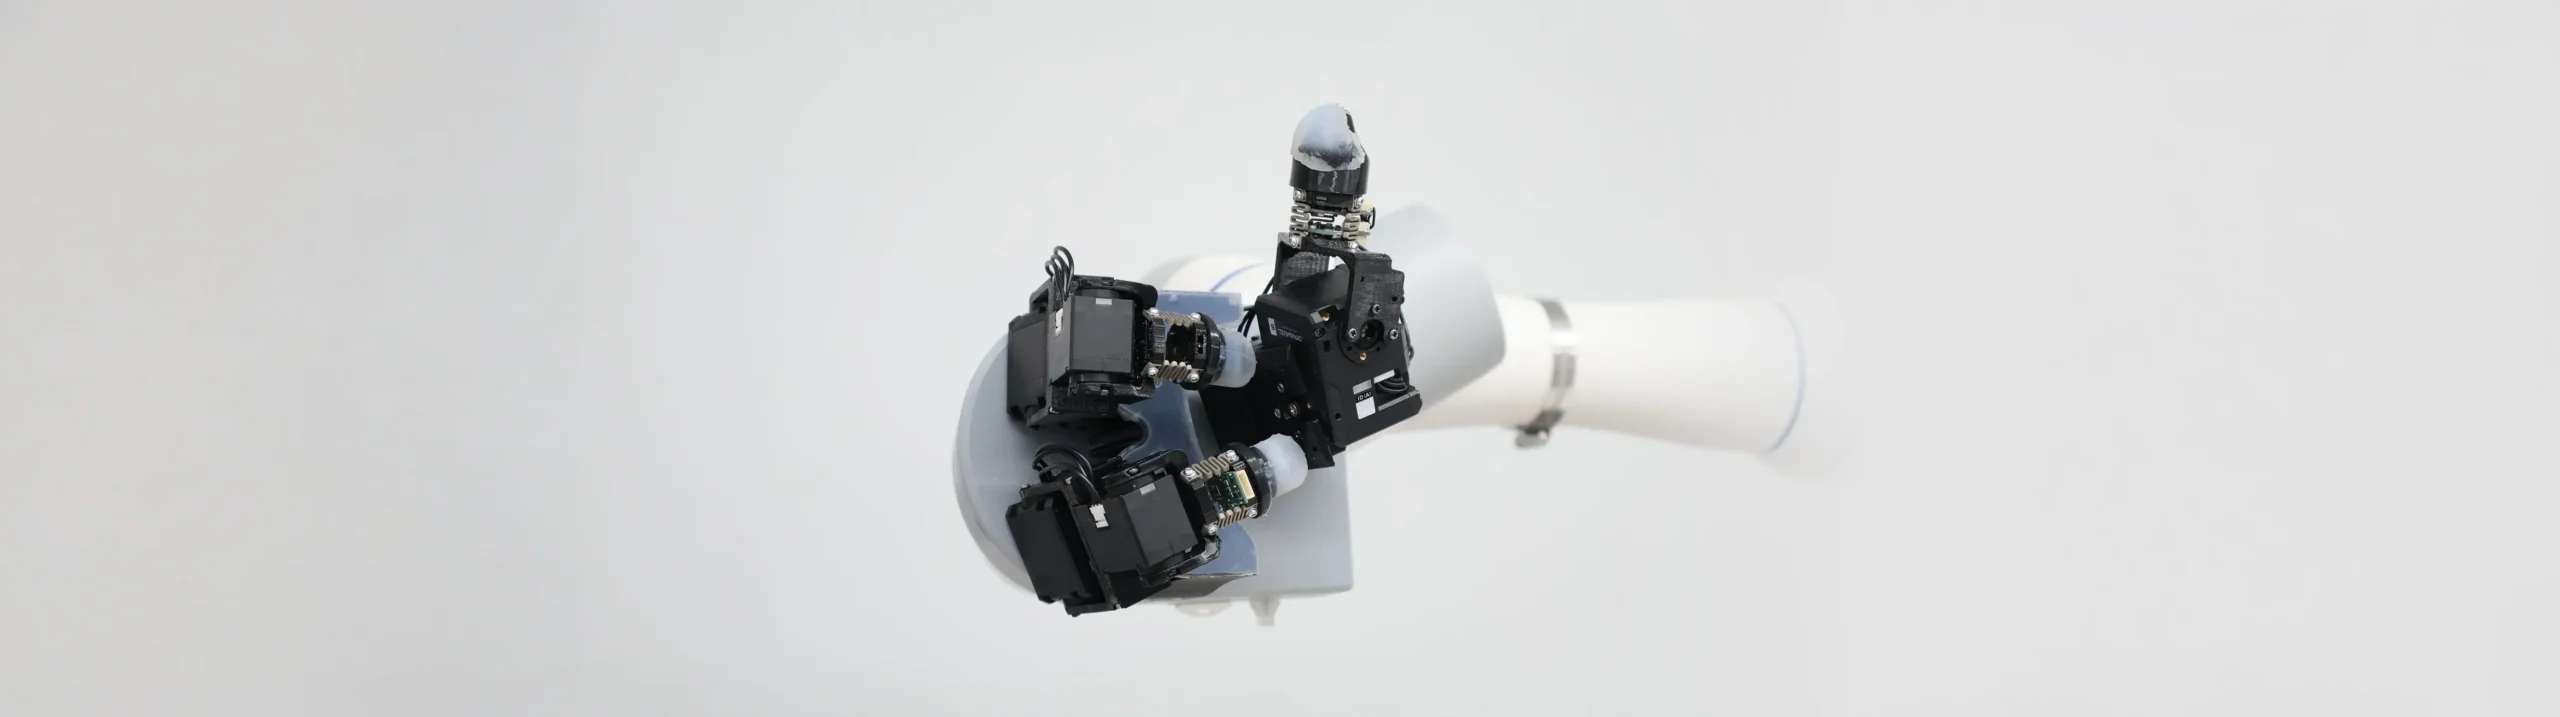
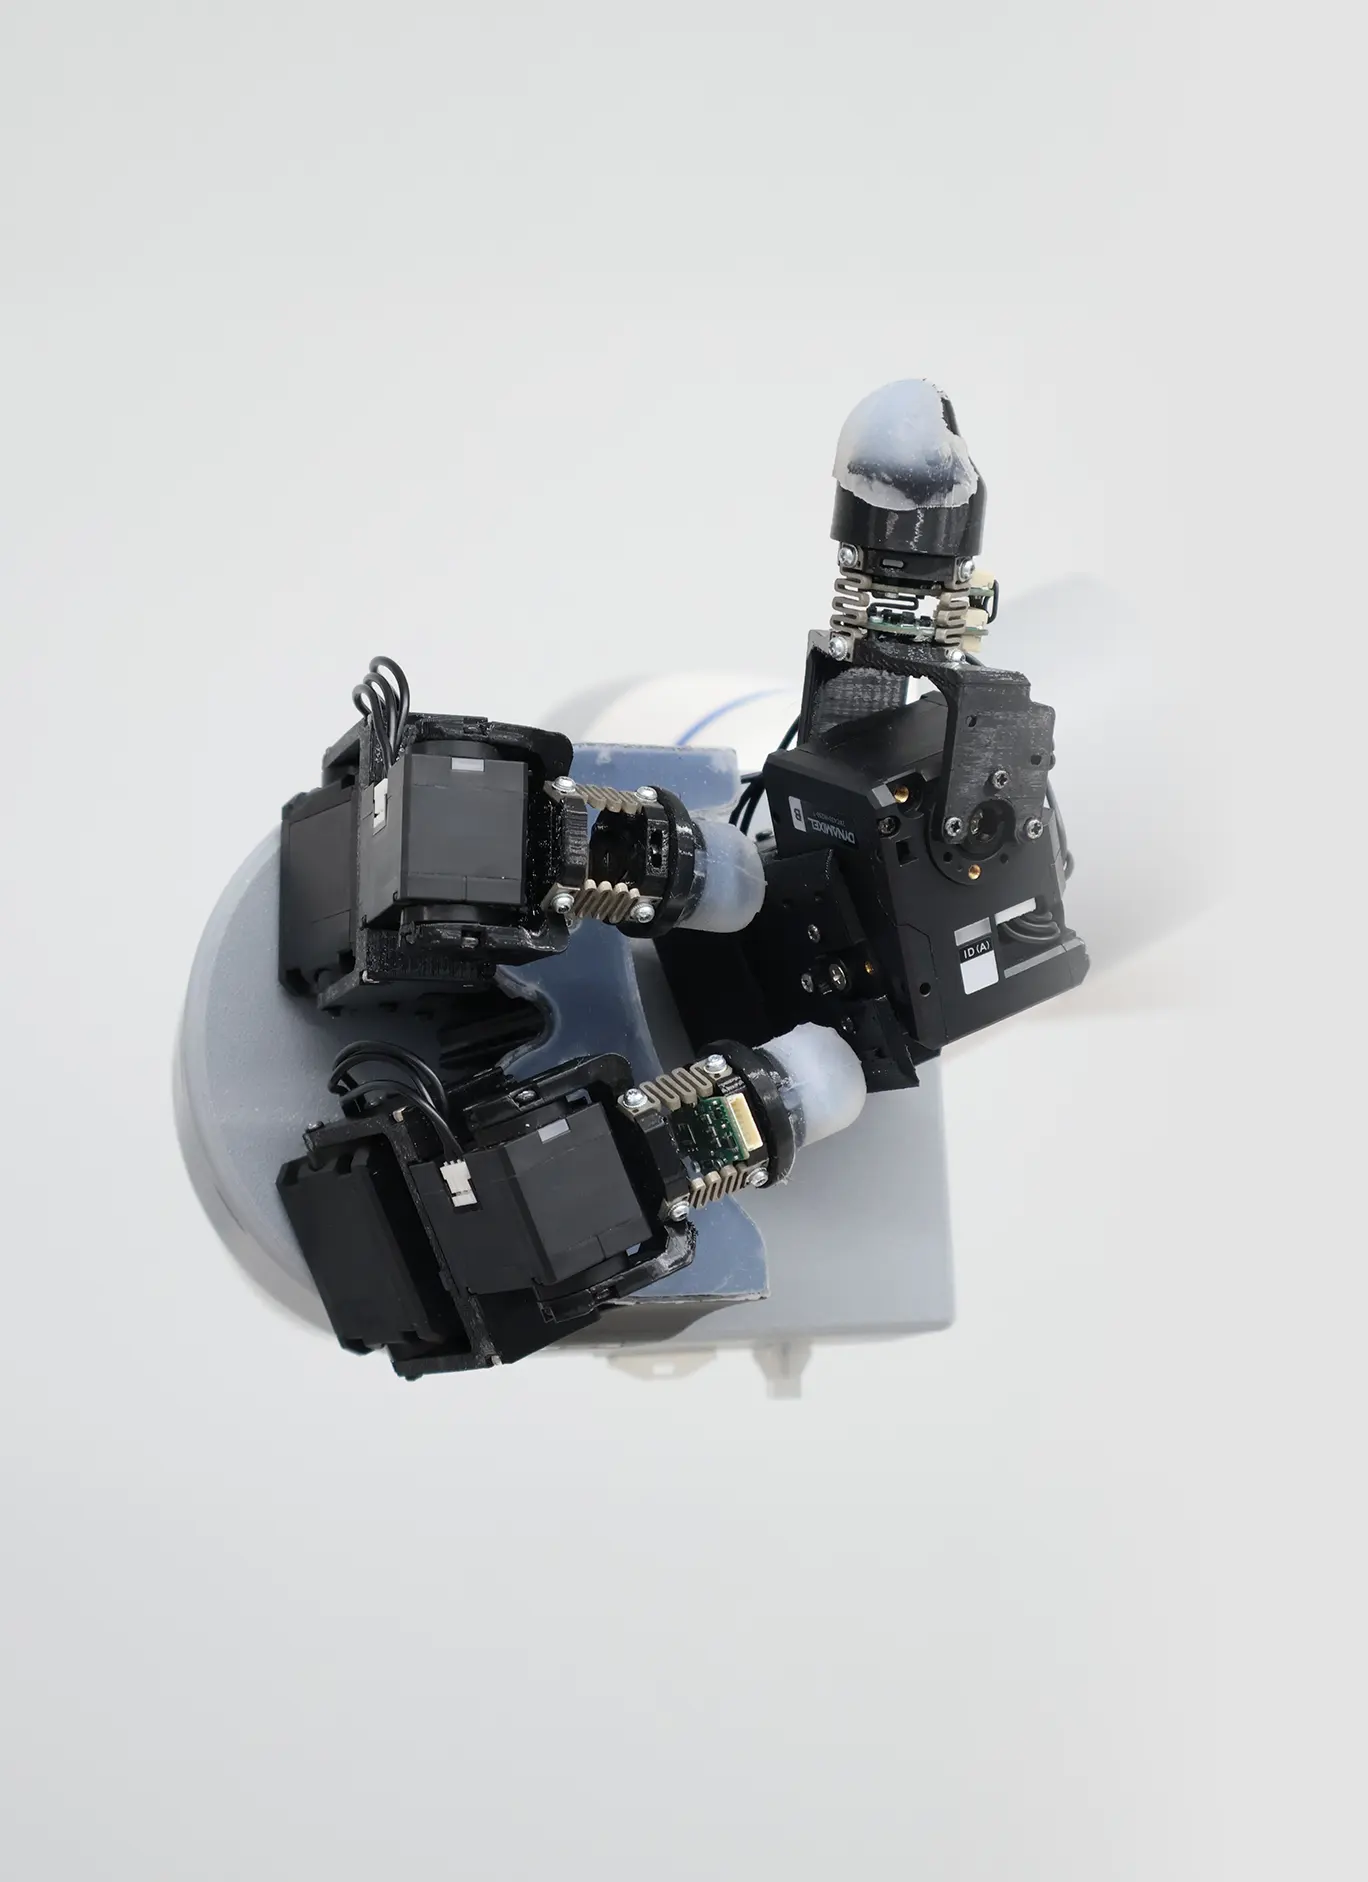
Have you ever wondered what more fingers on a (robot) hand buy you in terms of concrete capabilities? While the TR01 proved to be remarkably dexterous with two fingers, we designed and built the TR02 to add a number of specific abilities, by virtue of a third finger and a useful palm. The TR02 can perform more stable grasps, especially for heavy, large or elongated objects, reorient or move an object in-hand, lifting an object into the palm and wrap its fingers around it, stabilize and manipulate at the same time (such as holding a jar while opening its lid). Your hand does all these things on a daily basis — for example, every time you pick up your cellphone from a table, you transition it from the fingertips into your palm without even thinking about it. We’ve thrown in a creepy crawl just for fun.
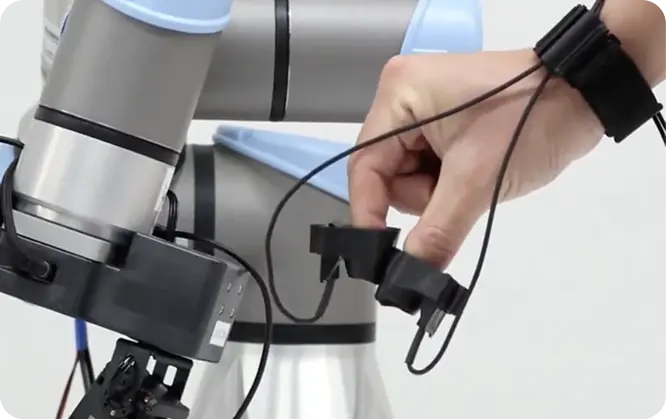
We’re big fans of adding complexity only in as much as it brings a provable, concrete gain in capabilities as well, and the TR02 is a product of this design philosophy. It also preserves the unique capability of the TR01 to perfectly match the movement of a human operator’s fingertips within a given workspace, preserving human-like thumb-to-index dexterity, and, of course, has Popcorn touch sensors integrated into every fingertip. We’ll be putting it through its paces alongside the TR01 in the coming weeks, in terms of autonomous skilled manipulation policies.
Technical Details
The TR02 has three fingers and 10 total degrees of freedom (four on the “thumb”, three each on the “index” and “middle” fingers). The thumb-to-index kinematic chain has seven degrees of freedom and allows full SE(3) positioning of the index tip relative to the thumb tip, allowing us to perfectly track human fingertip movement. The position of the middle finger tip is tracked as a secondary objective with lower weight: we assume that most delicate manipulation is performed between the thumb and index, and the middle finger is used primarily for stabilization and thus does not require exact tracking. In addition to tracking, the kinematics are designed to allow power (enveloping) grasps that also make use of the palm, and transitions where the hand “walks” the grasped object from a fingertip (precision) grasp into a power grasp. Three Popcorn sensors and an offset palm camera provide the sensor suite for upcoming policies trained on teleoperated data.